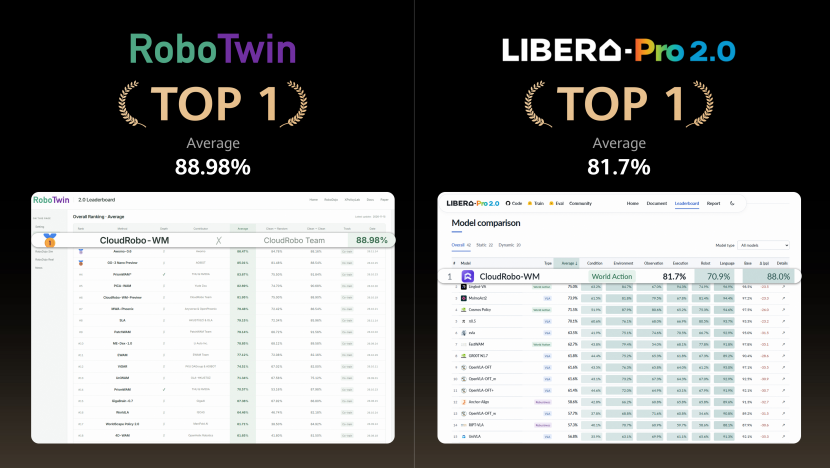
Huawei Cloud announced CloudRobo-WM1.2, an Ascend-native embodied world model, on November 16, 2026. As reported on November 20, the company planned to release the model weights, inference code and post-training code on November 30; the release had not yet taken place at the time of reporting.
The model is designed to connect predictions about the physical world with robot actions. Its predictive, physical-aware architecture aims to represent objects and anticipate changes during interactions. A DualAct design combines world modeling and action generation, while an MOT-based action expert offers another route for producing actions.
Huawei Cloud also described a training framework that can use data with missing action labels, incomplete camera views or other gaps, rather than discarding entire records. Its cross-embodiment motion modeling is intended to let robots with different forms—including single-arm, dual-arm and wheeled systems—share training data while retaining their distinct motion characteristics. For deployment, developers can choose among combinations of World/Expert Action and Joint/Action-only inference modes to balance compute needs and latency.
Huawei Cloud said CloudRobo-WM1.2 ranked first on both RoboTwin 2.0 and LiberoPro 2.0. The reported results are a company claim; the source does not provide independent test details. Huawei Cloud said its Ascend cloud platform would support training and deployment, and that it planned to open related tools and work with robotics companies, researchers and industry customers. Those plans do not establish how the model will perform in real-world deployments.